
Selected Projects
Current Project
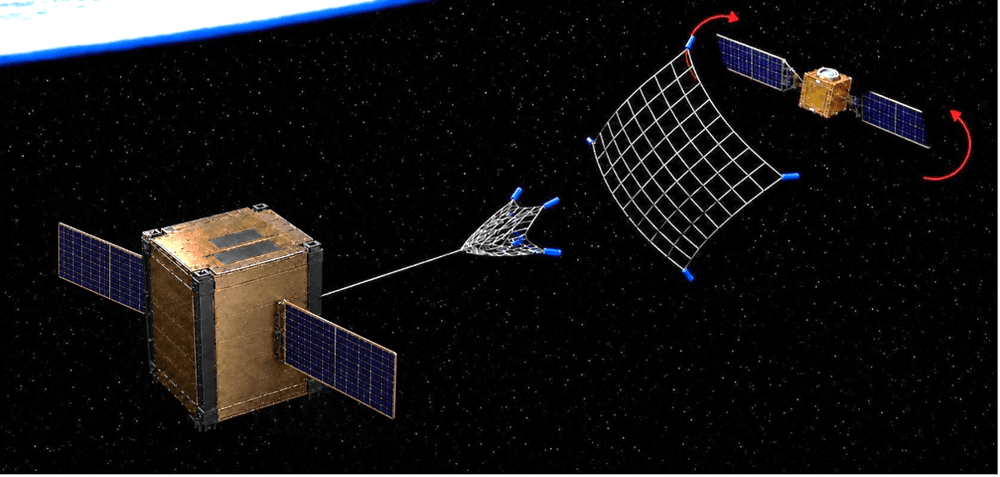
RIDDANCE: Removal of Irregular Debris using Double Assisted Nets with Controlled Enhancement
NASA / Orbotic Systems Inc.
Net-based capture of irregular debris requires an understanding of net deployment and interaction with the target. We develop capture-net prototypes and formulate the system dynamics. Planned experiments will assess capture performance and guide modifications to the net design.
Completed Project
Experimental Testbed for Development and Validation of Autonomous ISAM / OSAM Systems
Air Force / SpaceWERX / ControlX, Inc.
We designed and assembled a ground-vehicle testbed for developing and evaluating autonomous OSAM control methods, with planar motion on a low-friction epoxy floor and a robotic-arm attachment. To extend the testbed’s experimental capabilities within the constraints of ground testing under Earth’s gravity, we added a second platform that provides adjustable attitude.


Completed Project
Extended Research: Flexible Body Control Using Fiber Optic Sensors
Florida Space Grant Consortium
Uncertain structural parameters and neglected vibration modes can limit the performance of controllers designed for rigid-flexible vehicles, particularly when rigid and elastic motions are treated separately. We investigated their coupled dynamics and developed observer-based adaptive sliding-mode control for stabilization and trajectory tracking without requiring prior knowledge of uncertainty bounds. The formulation accommodates unmeasured states and different numbers of control inputs and measured outputs.
Publications
- Fagetti et al. (2025) · coupled dynamics and adaptive control of rigid-flexible vehiclesDOI: 10.1016/j.jfranklin.2025.107774


Completed Project
Development of an SE(3)-based Rigid Body Pose Estimation Scheme for Unknown Moments of Inertia
(Phases I, II, and III) NASA / A.I. Solutions, Inc.
Spacecraft mass, center of mass, and moments of inertia may be uncertain or vary during crewed and uncrewed operations as propellant is consumed or onboard mass is redistributed. Navigation and control systems must autonomously account for these uncertainties and changes in mass properties. To avoid singularities associated with minimal attitude parameterization sets and the nonuniqueness of quaternion representations, we developed geometric state and mass-property estimation on TSE(3), where rotation matrices are used to represent attitude. Thruster excitation supports identification of mass properties while accounting for coupled orbit-attitude motion and measurement noise. The associated studies examined dual and joint unscented filtering, square-root implementations, windowing for large initial uncertainties, and estimation with liquid-propellant slosh.
Publications and outreach
- Gunter et al. (2026) · square-root UKF state and mass-property estimationDOI: 10.1007/s40295-026-00634-7
- Mangiacapra et al. (2022) · geometric UKF and controlDOI: 10.1007/s11071-022-07293-x
- McCann et al. (2024) · ψ mapping and mass-property estimationDOI: 10.1016/j.actaastro.2024.07.011
- Fagetti et al. (2026) · joint and dual state and mass estimation with propellant sloshDOI: 10.1016/j.actaastro.2026.03.054
- Wittal et al. (2025) · launch-vehicle ambiguity and control with parameter uncertaintiesDOI: 10.2514/1.A36275
- Nazari et al. (2023) · inertia-property estimation with slosh dynamicsSIAM News

Completed Project
Reconfigurable Guidance and Control Systems for Emerging On-Orbit Servicing, Assembly, and Manufacturing (OSAM) Space Vehicles
Air Force / ControlX, Inc.
Capturing a noncooperative space object requires coordinated motion of the spacecraft bus and its manipulators, whose coupling complicates the governing dynamics and tracking control. We formulated the dynamics of a spacecraft with two robotic arms and developed sliding-mode control that accounts for their mutual interaction. The numerical results demonstrated that variational integration preserves the system geometry during propagation and that the controller guides the end-effectors toward designated contact points on the target.
Conference paper
- D’Eramo et al. (2025) · sliding-mode tracking control of a dual-arm space vehicleAAS/AIAA Space Flight Mechanics Meeting · paper record
Completed Project
Extension of Udwadia-Kalaba Constrained Motion Analysis on Lie Groups and their Tangent Bundles
Faculty Innovative Research in Science and Technology
Spacecraft control methods often treat translational and rotational motion separately. This makes it difficult to account for their coupling while accommodating additional constraints. We extended the Udwadia-Kalaba formulation within geometric mechanics to determine the forces and torques required to achieve and maintain constrained rigid-body motion. The formulation can be extended to multibody systems.
Publications
- Memon et al. (2021) · fuel efficiency of constrained Coulomb formationsDOI: 10.1109/TAES.2021.3090920
- McCann & Nazari (2022) · constrained rigid-body motion on Lie groupsDOI: 10.3934/jgm.2022002
Completed Project
College of Engineering Summer Research Stimulus Program
ERAU College of Engineering