
Our group studies coupled orbital and attitude dynamics in complex spaceflight environments and develops geometric methods for modeling, estimation, optimization, and control of space systems.
Our Group

Morad Nazari
Associate Professor of Aerospace Engineering
University of Nevada, Reno
mnazari [at] unr [dot] edu
Palmer Engineering, PE 218; Mail Stop 0312
1664 N. Virginia Street, Reno, NV 89557
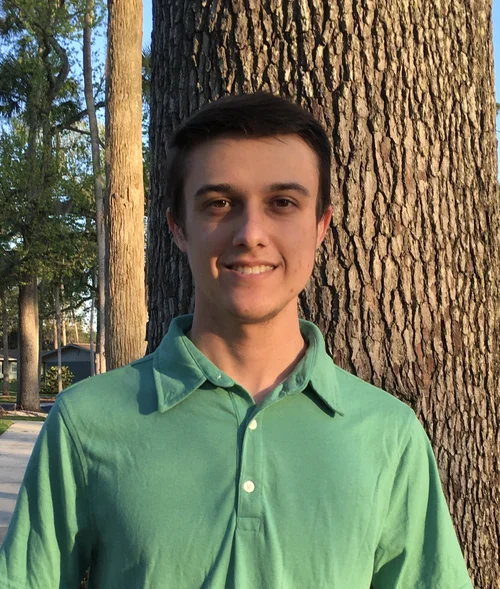
Marco Fagetti
Marco Fagetti started his MS-PhD education in January 2022. His research areas include spacecraft guidance, navigation and control, astrodynamics, and rigid-body coupled dynamics.
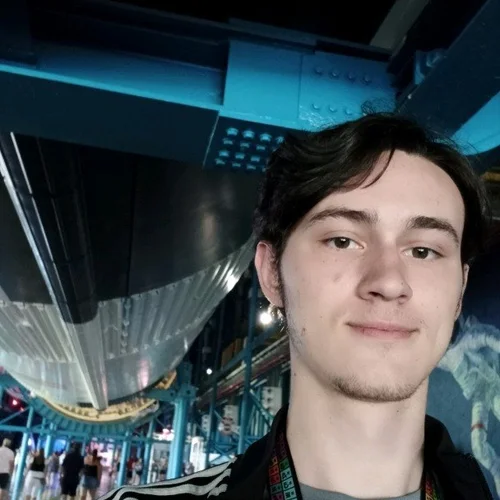
Herman Gunter V
Herman Gunter V started his MS-PhD education in January 2024. His research areas include rigid body parameter estimation, cislunar astrodynamics, and rigid body coupled dynamics.

Aiden Baker
Joined the research group as a graduate student in August 2026.
Research Interest
Astrodynamics
Higher-degree gravity and full N-body dynamics in cislunar and binary systems.
Explore research →Nonlinear Dynamics, Estimation, and Control
Geometric state and parameter estimation
Explore research →Optimization on Riemannian Manifolds
Geometry-preserving optimization of rigid-body attitude and pose.
Explore research →Publications
- [J34] H. Gunter, M. Fagetti, M. Nazari, M. M. Wittal, and J. D. Smith, Nonlinear State and Mass Property Estimation via Square-Root Unscented Kalman Filter on TSE(3) with Windowing Function, Journal of Astronautical Sciences, 73(96): 1–46, 2026, doi: 10.1007/s40295-026-00634-7
- [J33] M. Fagetti, H. Gunter V, and M. Nazari, M. M. Wittal, M. Elmore, and J. D. Smith, State and Mass Estimation for Spacecraft with Slosh: Dual vs. Joint Methods, Acta Astronautica, 246: 1-18, 2026, doi: 10.1016/j.actaastro.2026.03.054
- [J32] S. G. Jo, D. Canales, D. Seo, and M. Nazari, Adaptive Attitude-Orbit Control via Noncertainty Equivalence in the Cislunar Region, 152(B), 2026, doi: 10.1016/j.cnsns.2025.109218
Selected Projects
Current Project
- RIDDANCE: Removal of Irregular Debris using Double Assisted Nets with Controlled Enhancement
Completed Projects
- Experimental Testbed for Development and Validation of Autonomous ISAM / OSAM Systems
- Extended Research: Flexible Body Control Using Fiber Optic Sensors
- Development of an SE(3)-based Rigid Body Pose Estimation Scheme for Unknown Moments of Inertia
- Reconfigurable Guidance and Control Systems for Emerging On-Orbit Servicing, Assembly, and Manufacturing (OSAM) Space Vehicles
- Extension of Udwadia-Kalaba Constrained Motion Analysis on Lie Groups and their Tangent Bundles
- College of Engineering Summer Research Stimulus Program
Group Updates
Aug 2026: Aiden Baker joined the research group as a graduate student. Welcome, Aiden!
Aug 2026: Morad Nazari joined the faculty of Aerospace Engineering at University of Nevada, Reno.
Apr 2025: Herman Gunter V defended his MS thesis “Robust Adaptive Rigid Body State and Mass Property Estimation via Unscented Kalman Filter on TSE(3) with Process Noise Estimation” and continues his education towards PhD.
Apr 2025: Matthew Wittal defended his PhD dissertation “Robust Spacecraft Autonomy for Deep Space Exploration in Special Euclidean Group SE(3)”.